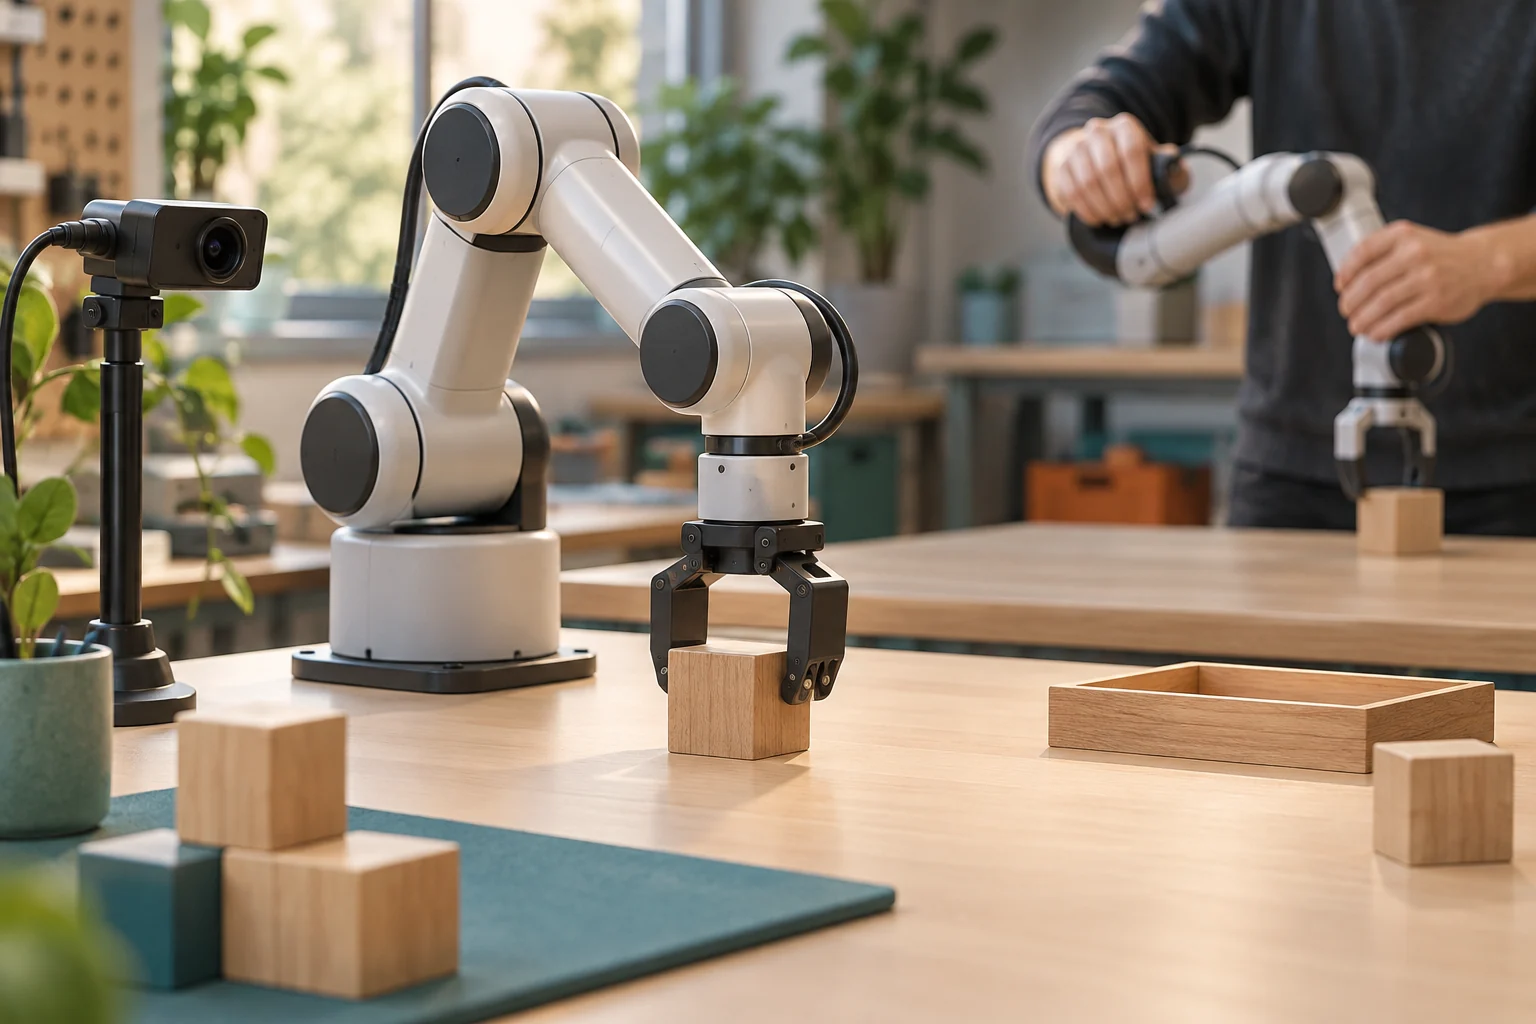
Robot Learning: A Tutorial (From Classical Robotics to Generalist Policies)
A practical way to start robot learning is to teleoperate one task, train an imitation policy such as ACT, and evaluate it on the same hardware under controlled conditions. Classical control handles joints and motion; the learned policy selects actions from observations. A VLA adds language instructions and pretraining, but calibration, data collection, and physical evaluation remain necessary. LeRobot’s official documentation also recommends ACT as a first policy.
Read MoreTags
- A2a
- Act
- Agent
- Agent-Debate
- Agent-Finance
- Agent-Harness
- Agent-Skills
- Agentic-Payments
- Ai-Agent
- Ai-Agents
- Ai-Architecture
- Ai-Blockchain
- Ai-Research
- Ai-Search
- Ai-Security
- Akash
- Anthropic
- Apify
- Base
- Benchmark
- Besu
- Bitcoin
- Bittensor
- Block-Access-Lists
- Canton
- Capital-Markets
- Ccip
- Cctp
- Chainlink
- Circle
- Coding
- Coding-Agent
- Coinbase
- Commerce
- Competition
- Compliance
- Context-Engineering
- Cross-Chain
- Cryptography
- Daml
- Data
- Data-Enclosure
- Data-Licensing
- Decentralized-Compute
- Depin
- Dex
- Diffusion-Policy
- Distillation
- Eip
- Eip-2780
- Eip-3009
- Eip-8037
- Eip-8038
- Emergent-Behavior
- Ensemble
- Enterprise-Blockchain
- Epbs
- Erc-8001
- Erc-8004
- Erc-8041
- Erc-8126
- Erc-8183
- Erc-8196
- Erc-8226
- Ethereum
- Evals
- Evaluation
- Evm
- Execution-Client
- Fhe
- Fido2
- Fintech
- Gas
- Glamsterdam
- Goldman-Sachs
- Google-Cloud
- Gpt-5-6
- Groth16
- Harness
- Heloc
- Hermes-Agent
- Identity
- Imitation-Learning
- Institutional-Finance
- Kimi
- Knowledge-Management
- Kya
- Langfuse
- Langgraph
- Lerobot
- Llama-Cpp
- Llm
- Llm-Agents
- Llm-as-Judge
- Llm-Observability
- Local-Llm
- Maci
- Math
- Mcp
- Memory
- Metadata
- Mev
- Moa
- Model-Routing
- Moe
- Mpp
- Mtp
- Multi-Agent
- Observability
- Okf
- Onchain
- Open-Source
- Open-Standard
- Opik
- Orderbook
- Passkey
- Physical-Ai
- Platforms
- Post-Quantum-Cryptography
- Post-Training
- Privacy
- Prompt-Engineering
- Provenance
- Python
- Qbft
- Quant-Finance
- Quantum-Computing
- Qwen
- Rag
- Reasoning
- Reinforcement-Learning
- Render
- Reputation
- Retrieval
- Reverse-Kl
- Rl
- Robot-Learning
- Rwa
- Search-Agent
- Security
- Self-Improvement
- Semaphore
- Settlement
- Skills
- Small-Language-Model
- Smart-Contract
- Smart-Contracts
- Smolvla
- Snark
- Software
- Solidity
- Sp1
- Stablecoin
- Stigmergy
- Swe-Bench
- Tokenization
- Tracing
- Trading
- Tutorial
- Ucp
- Uncensored
- Usdc
- Validators
- Vla
- Voting
- Wallet
- Webauthn
- X402
- Ylds
- Zero-Knowledge
- Zk-Proof
- Zk-Rollup